6-axis gyro
Accelerometer and gyro in one sensor. The timer tracks the model's attitude on the hemisphere for the whole flight: elevation, climb or dive angle, and the rotation in every maneuver.
The active timer for F2B control line, now set up from your phone. Your Jeti SPIN too: no JetiBox, no unplugging.
The big one
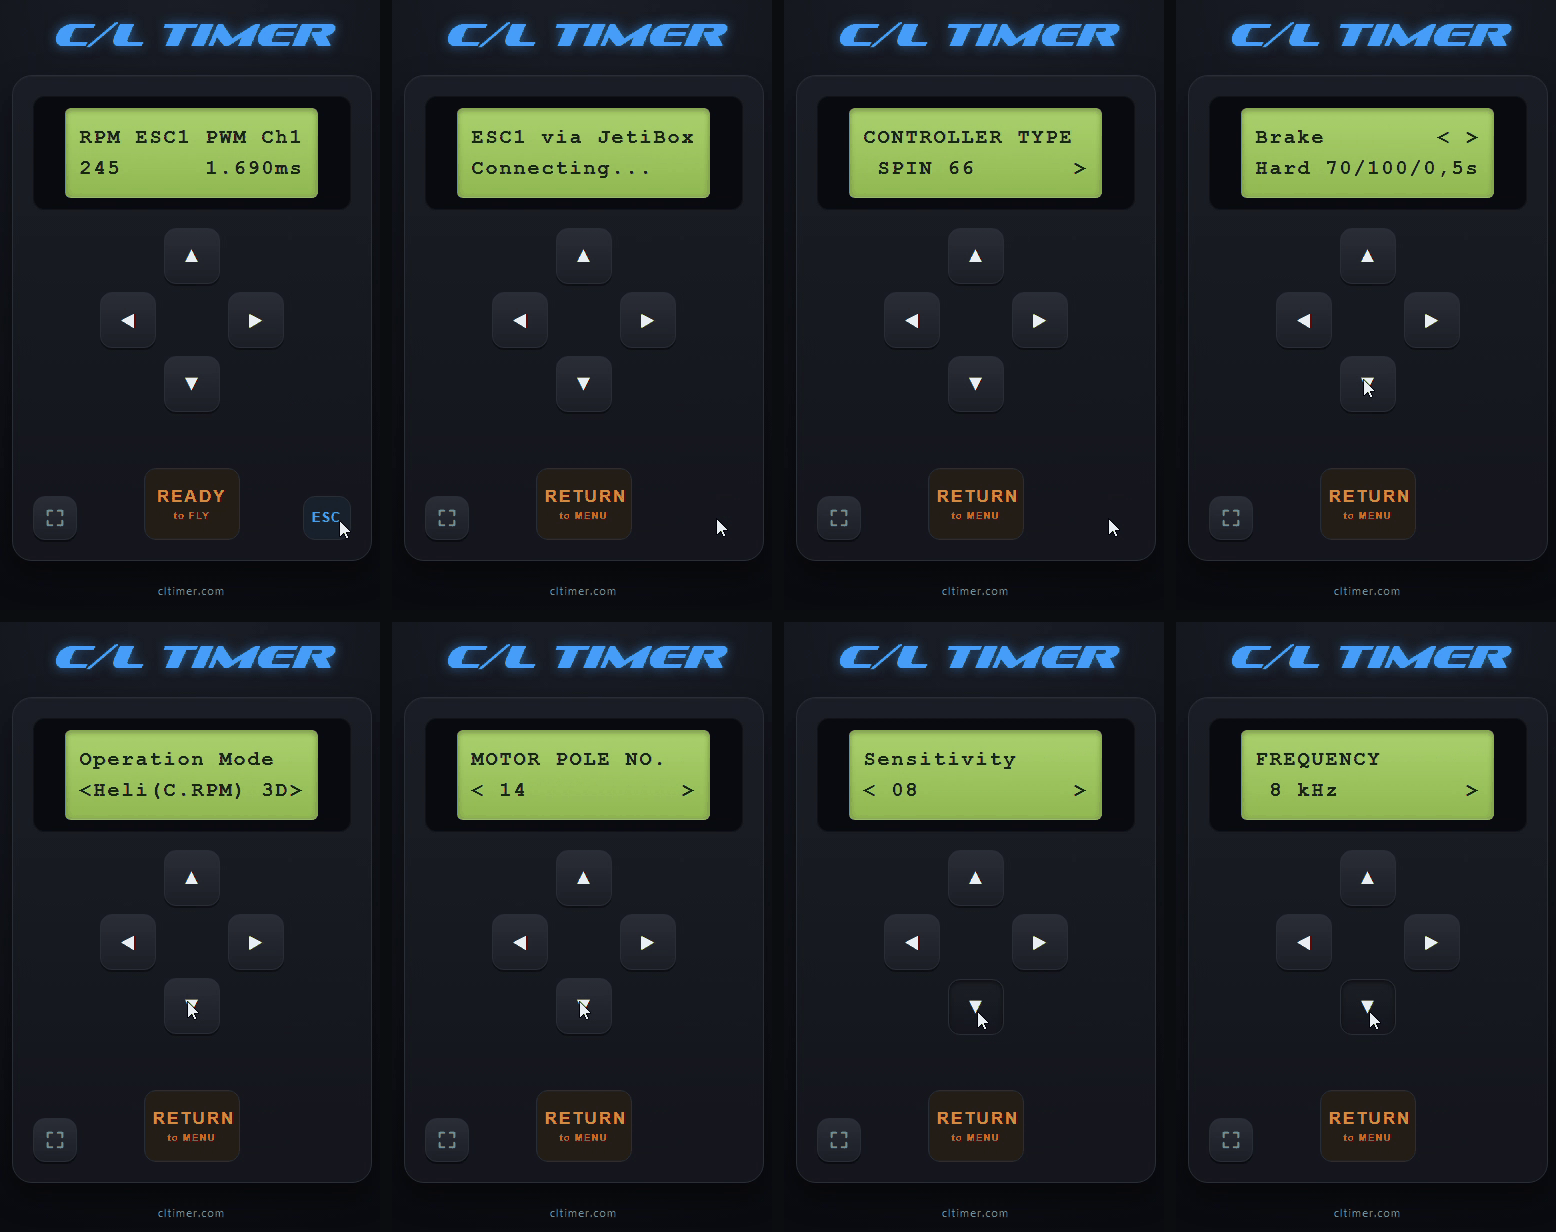
On the RPM screen there is an ESC button. One tap and the timer connects to the SPIN, and the full SPIN menu appears on your phone, with the ESC connected to the timer exactly as in flight.
What is new in V7
The timer creates its own Wi-Fi network. Connect a phone or computer and the familiar 16x2 screen with the four arrows appears in the browser. No app to install.
Accelerometer and gyro in one sensor. The timer tracks the model's attitude on the hemisphere for the whole flight: elevation, climb or dive angle, and the rotation in every maneuver.
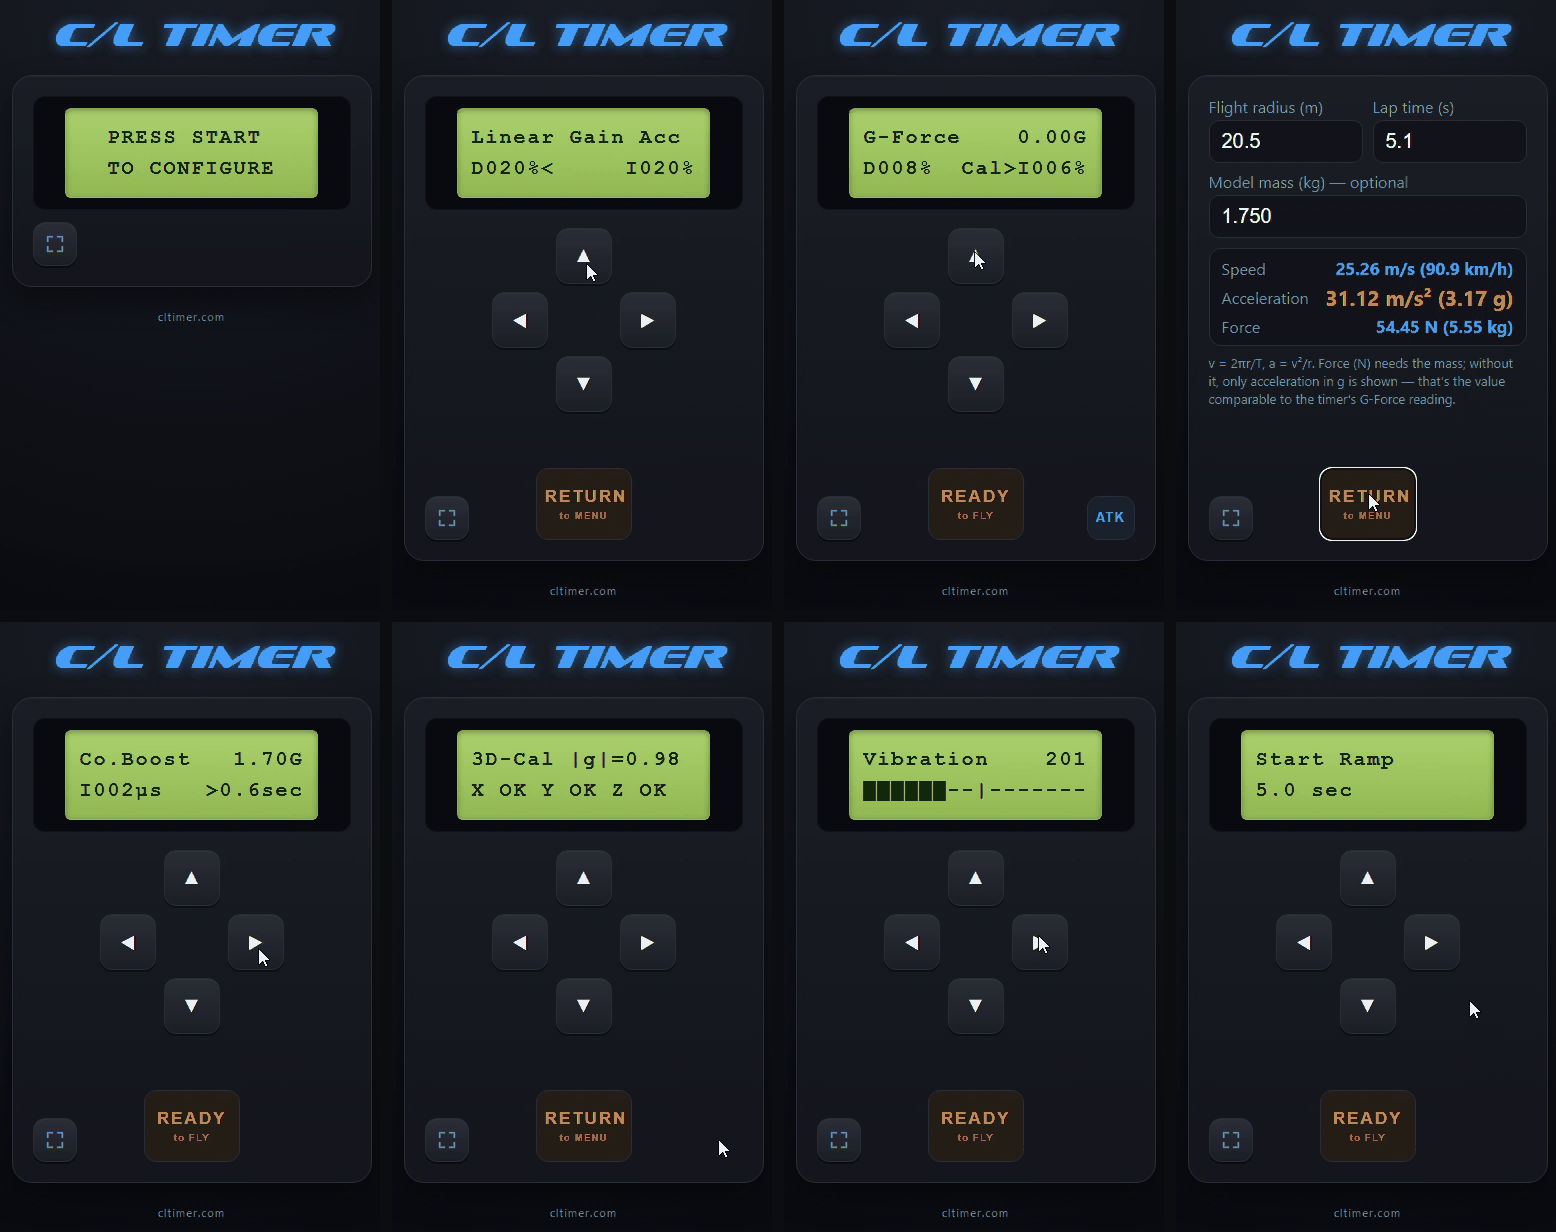
The Speed screen shows the level-flight speed, lap time and radius, measured by the gyro on the last flight. The RAD button sets the line radius, or leaves it on Auto.
A short RPM boost in the G+ and G− corners. The gyro recognizes the corner right at its start, and the boost adds to what the governor already asks. You set how much and for how long.
The RPM increase in climbs uses the real flight-path angle measured by the gyro, and anticipates the pull-up. Set the start angle (DW) and the maximum elevation (UP).
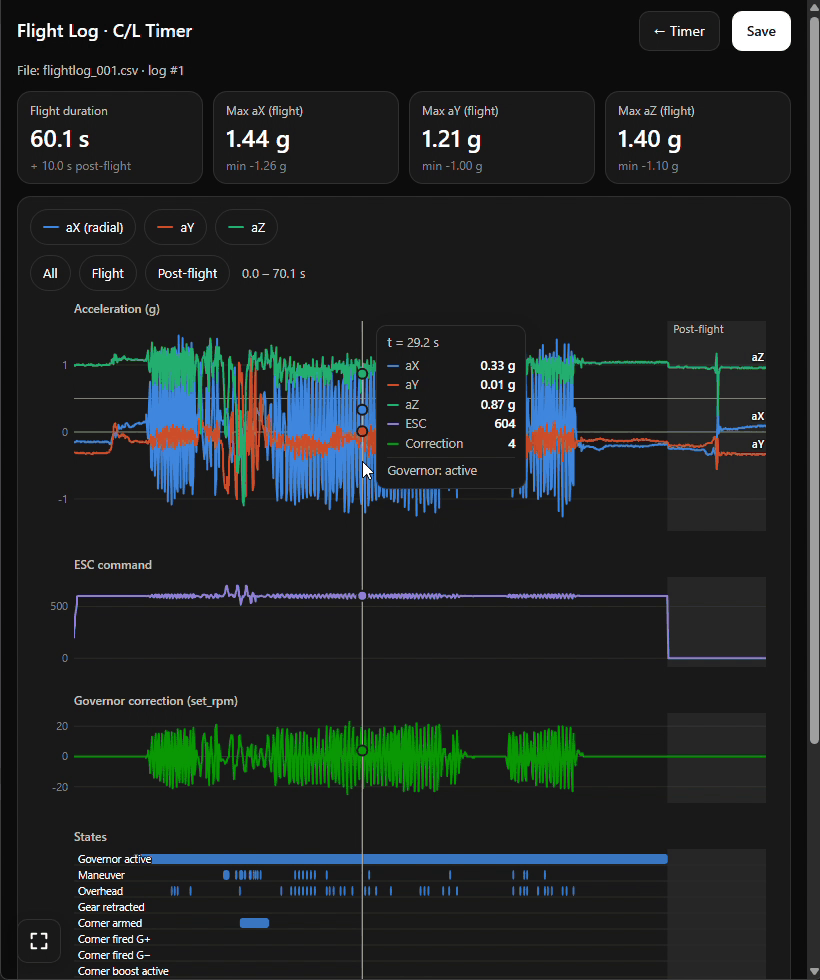
Every flight is recorded at 20 samples per second: acceleration on 3 axes with the real G up to 16 g, gyro, speed, ESC command and governor correction, plus all the settings used. See the graphs on your phone right after landing.
When a phone connects, the menu is locked. One tap on the timer button unlocks it, so only the person holding the model can change settings. Wi-Fi is off during the flight, and the flight only starts from the timer button.
Sensor calibration in 6 positions. The timer finds the sensor orientation by itself, and at the end it shows 1.00 g in any position to confirm the calibration.
Independent Decrease and Increase gains, for acceleration along the flight path (Linear) and for line tension (Centripetal).
G-Force with Decrease and Increase, an attack curve with a G limit, and a built-in calculator: line radius, lap time and model weight give the target G and the line pull.
The vibration peak of every flight on a bar. Past the middle mark, balance the prop or check the motor mount, before it shakes the model and the sensor readings.
A soft start: the motor rises smoothly to the flight RPM in up to 5 seconds, instead of jumping. Less torque kick, less stress on prop, motor and battery.
No need to send the timer to Brazil. Your settings are kept.
Timer board 20 x 26 mm (0.8 x 1.0 in) and sensor board 17 x 32 mm (0.7 x 1.3 in), 14 g (0.5 oz) together.
Automatic overhead protection, external LED with signalling modes, second motor with RPM offset, retractable landing gear and Safety Gear.
Many of these features came straight from flyers' requests on the Stunt Hangar forum over the last years.
See it working
The final V7 board, now with the gyro, is in production. Price and availability are not defined yet. Follow the preview and leave your comments on the Stunt Hangar forum.
Available now
The active timer that flies today. Programmed with the Jeti Box.
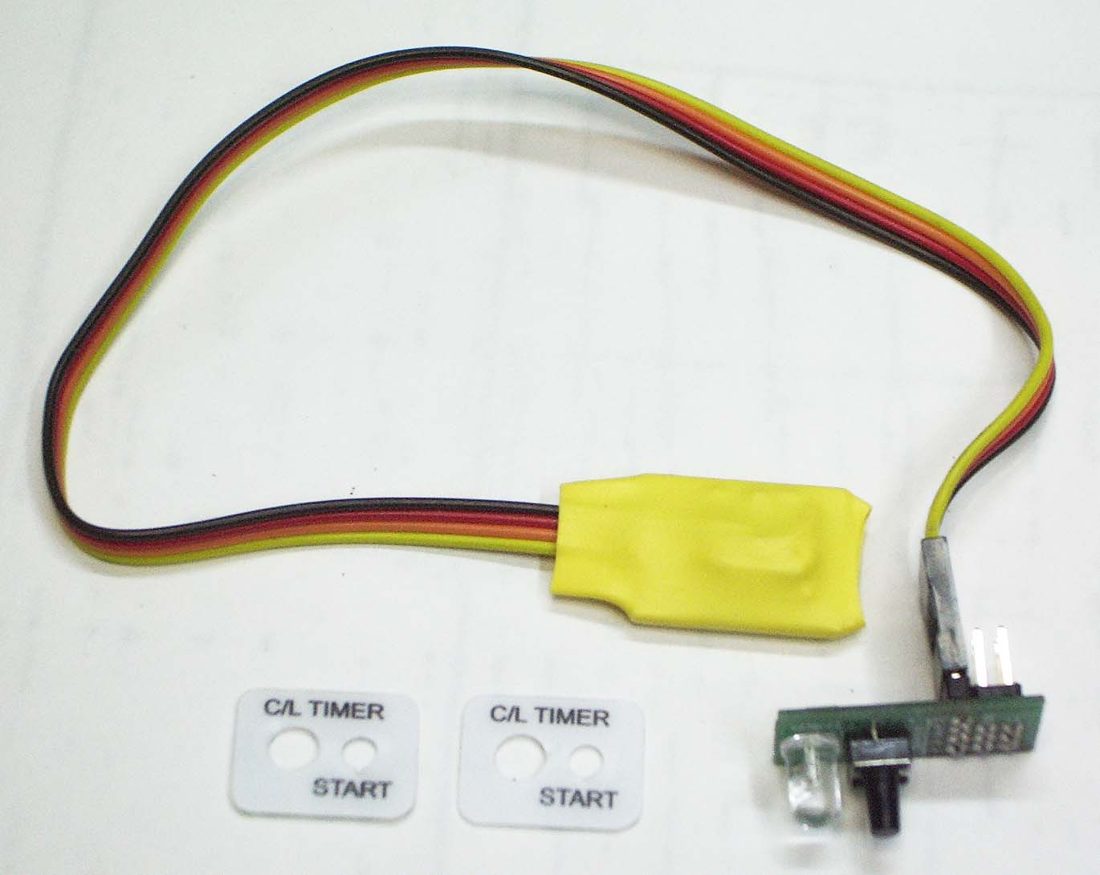
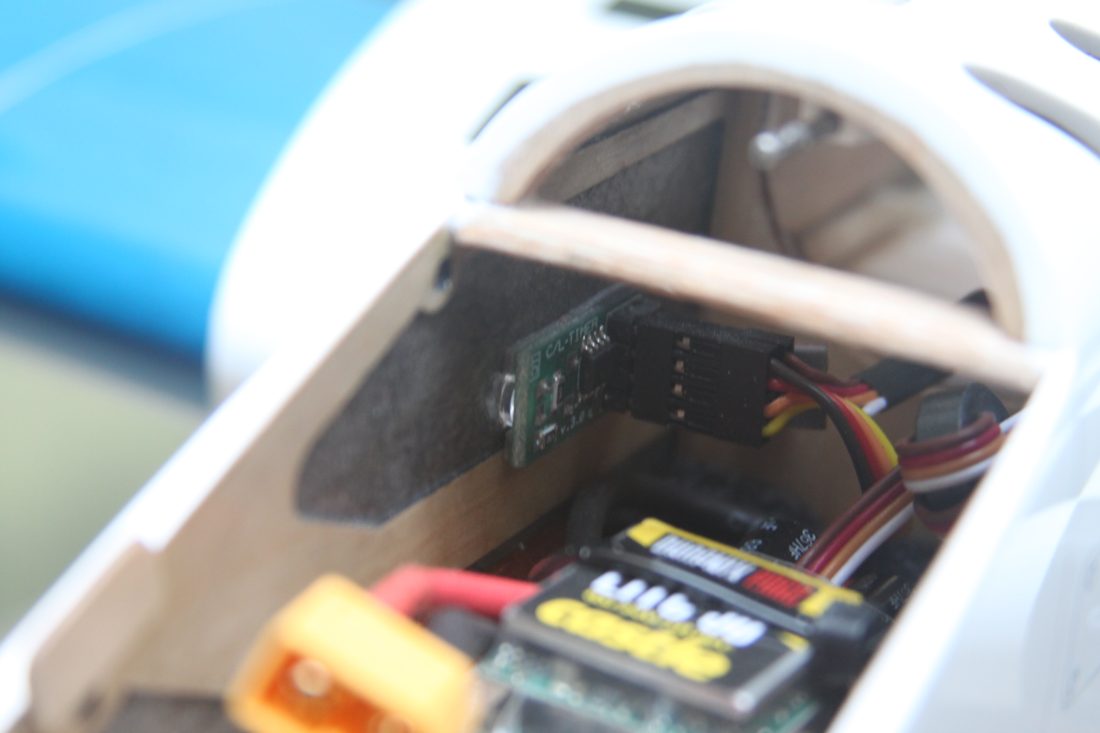
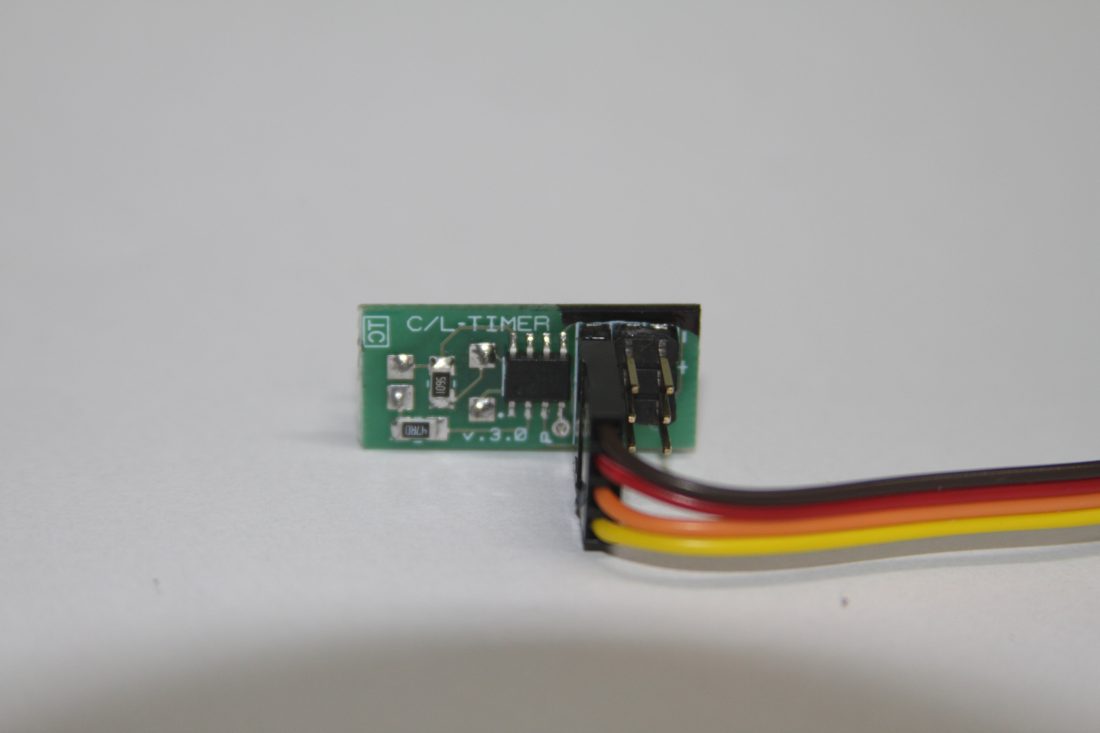
The timer controls the ESC to regulate the motor RPM in flight, based on the accelerometer. It can minimize the flight speed variation, or increase and decrease the RPM based on the accelerometer. A nose-up climb can simulate 4-2-4 type motor speed changes. Flight start delay and flight time are set with the Jeti Box.
The LED signals the start and the end of the flight, so a stopwatch is not needed. The 10-second warning lets you position the model for landing.
The V6 cannot be upgraded to V7: the V7 is a new board, with a new processor and Wi-Fi.
Files
Online tool
Open a flight log saved from your V7 timer and see the graphs: acceleration on 3 axes, speed measured by the gyro, ESC command, governor correction, every event of the flight and all the settings used.
It runs in your browser. The file is not uploaded anywhere.
Contact